Windsor. As-builts without a surveyor shadowing every pour.
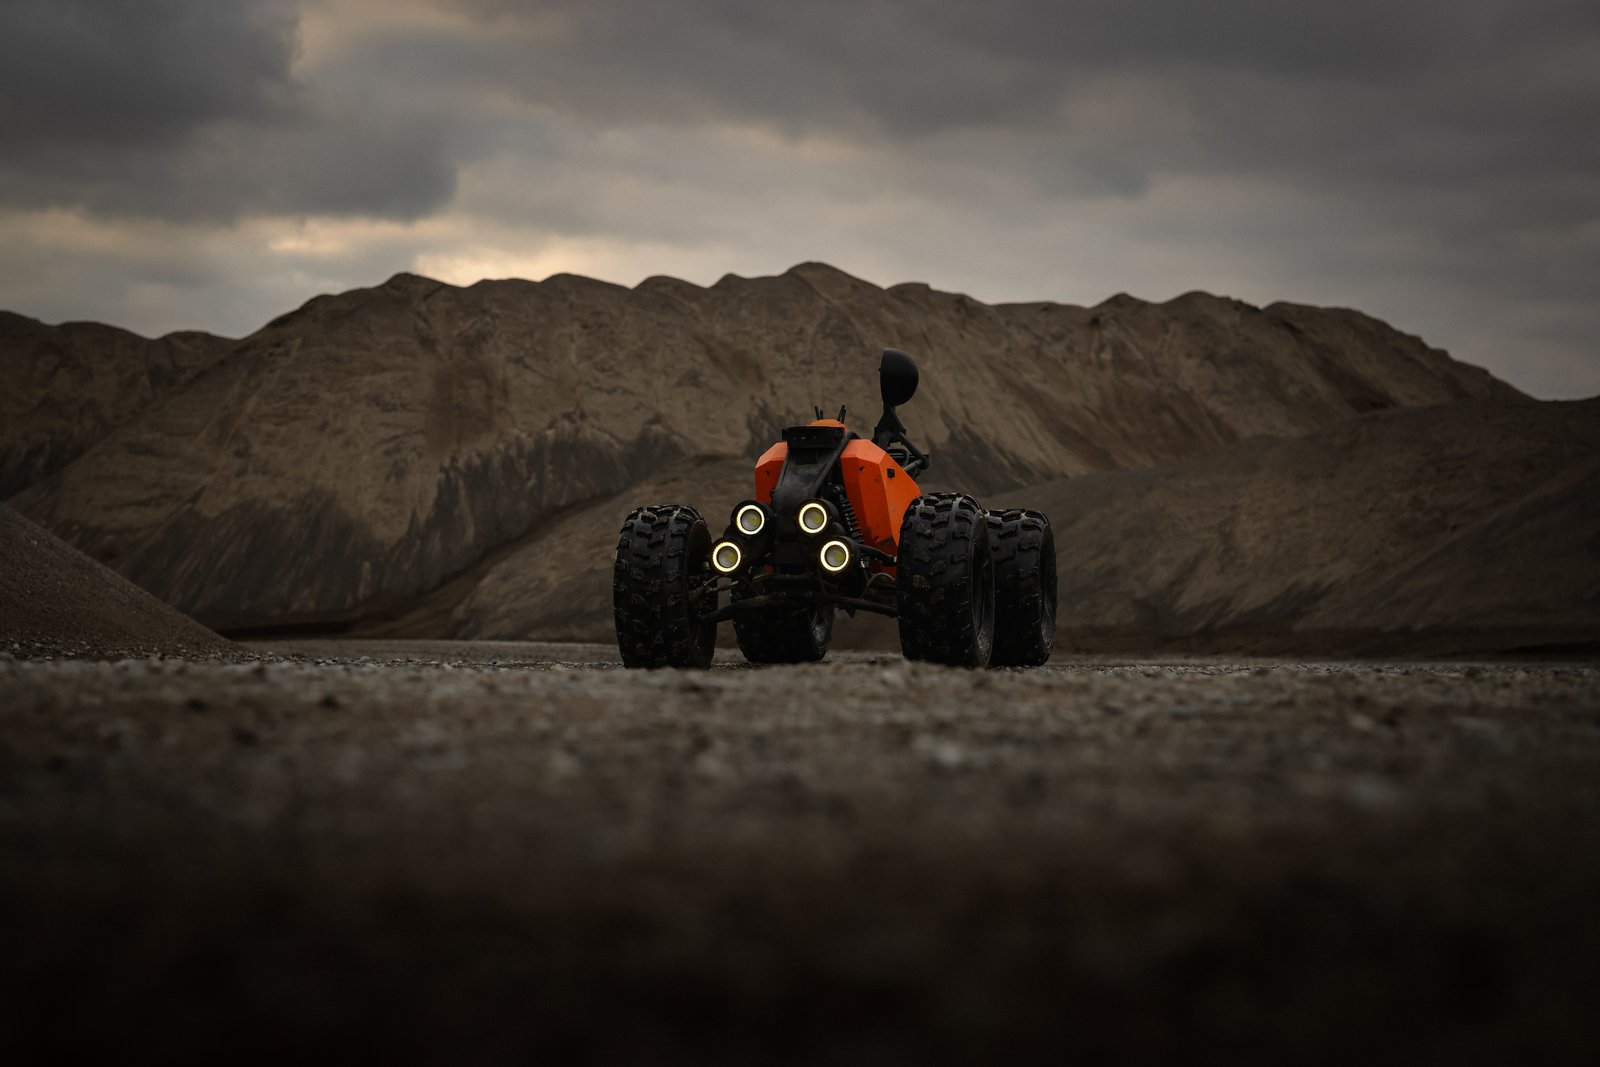
u-blox’s public case study on Optimotive covers Iris-class autonomous field robots built to collect surveying, scanning, and inspection data outdoors - the walk a survey crew still owns on big civil and industrial sites.
RTK positioning is part of the published stack so missions stay georeferenced without babysitting every waypoint. Equipment World also covered an Iris MK2 intro; Cloudflare blocked the fetch here, so the u-blox case is the verified text source for this dispatch.
Documentation robots only matter if they show up every morning. Iris is Optimotive’s answer in the FoB yard file. Read the source: https://www.u-blox.com/en/case-study/autonomous-field-robots-rtk-data-collection
 Optimotive